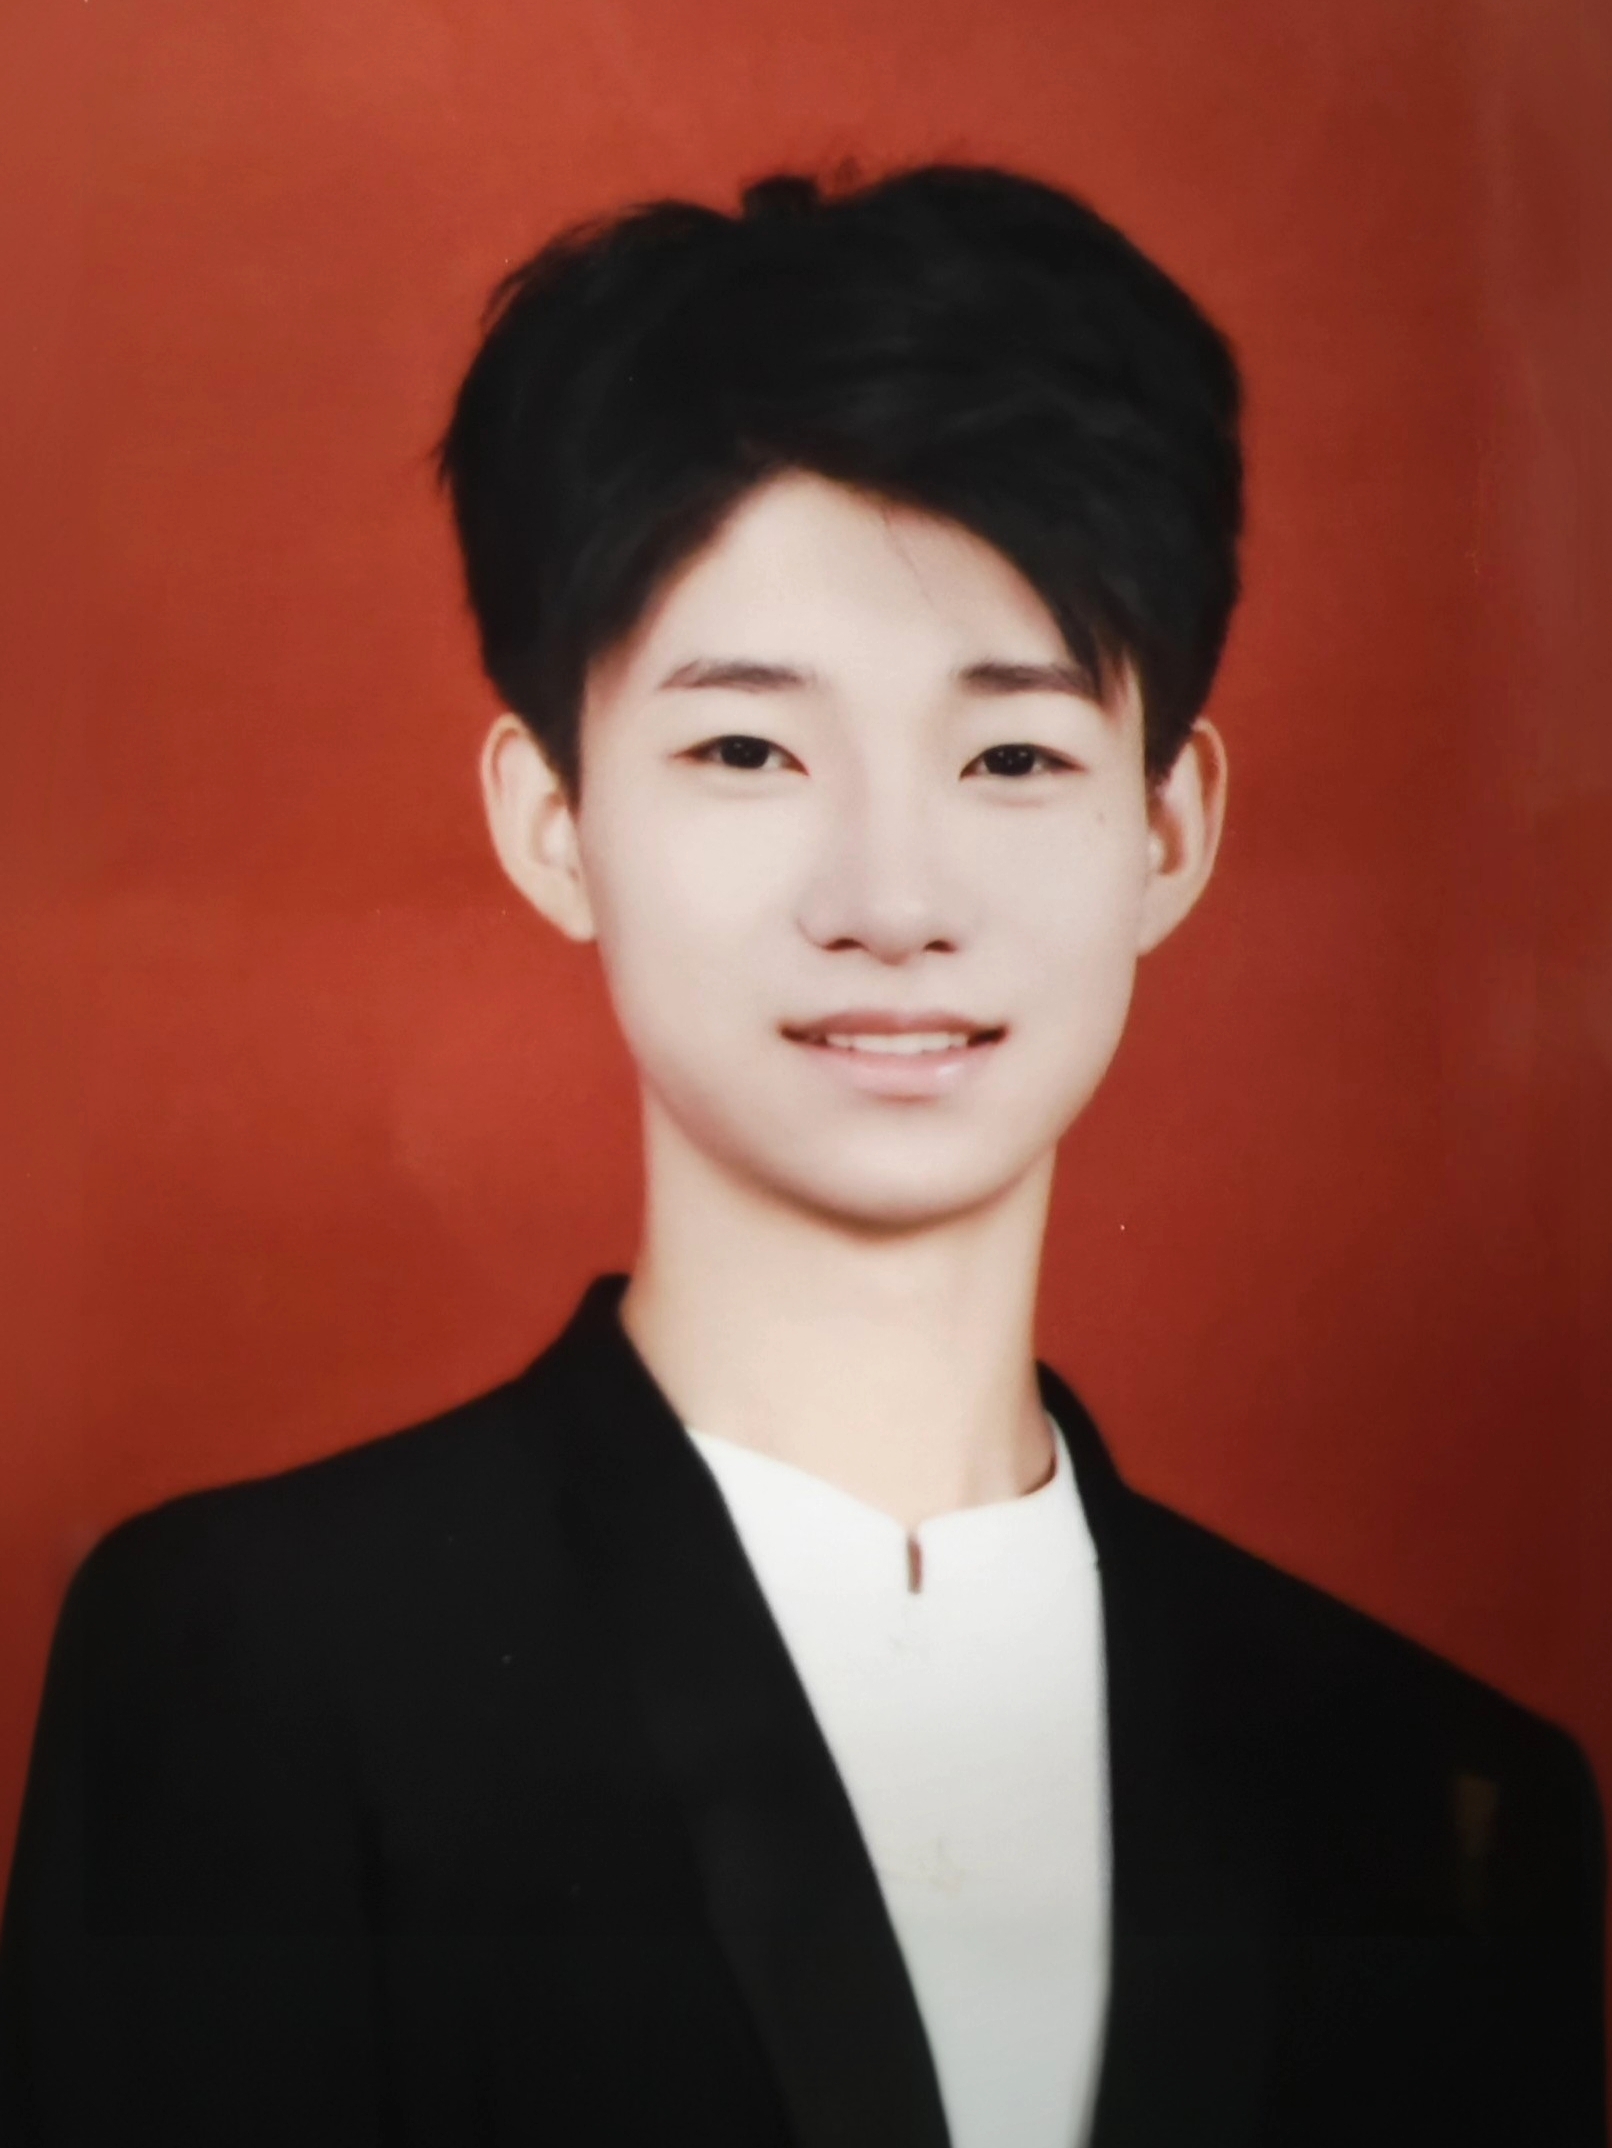
Robot Learning Embodied Intelligence

Xiangyu (Xavier) Wang

Undergraduate researcher working on robot learning and embodied intelligence.

I am an undergraduate at the University of Electronic Science and Technology of China (UESTC), currently conducting full-time, on-site research at Shanghai Qi Zhi Institute. Advised by Prof. Huazhe Xu of Tsinghua University, I work on robot learning and embodied intelligence with physical robots and real-world experimentation.

Previously, I worked with Prof. Zhao Kang at UESTC on graph machine learning, graph prompting, optimal transport, and intrinsic graph geometry. This work led to a TPAMI manuscript currently under major revision and a NeurIPS 2026 submission under review.

My current interests include generative robot policies, action representation, temporal modeling, reinforcement and imitation learning, and learning from real-world interaction.

Xiangyu Wang

Publications

Preserving Geometric Integrity in Graph Prompting via Measure-Constrained Optimal Transport

Xiangyu Wang*, Shuo Wang*, Ruiyi Fang, Zhao Kang

* Equal contribution

IEEE Transactions on Pattern Analysis and Machine Intelligence (TPAMI)Major Revision2026

Graph prompting often makes locally plausible routing decisions that nevertheless collapse onto a small prompt bank globally. MINT uses fixed-marginal optimal transport to control prompt capacity while preserving semantic compatibility; a variance decomposition clarifies the resulting geometry, and complementary topology adaptation supports gains across homophilic and heterophilic benchmarks.

The Post-GCN Decade Revisited: Curvature-Stratified Evaluation of Relational Learning

Shuo Wang*, Xiangyu Wang*, Quanxin Wang, Bailin Wu, Bokui Wang, Shunyang Huang, Boyan Deng, Haonan Liu, Ruiyi Fang, Zhenxiang Xu, Boyu Wang, Zhao Kang

* Equal contribution

NeurIPS 2026Under ReviewarXiv preprint

This work asks how intrinsic graph geometry changes the evaluation of relational learning. Across 18 models and 14 datasets stratified by curvature, model rankings and trade-offs vary with geometric regime, showing how a flat leaderboard can hide meaningful structure.

Background

2026.07 – 2027.01

Shanghai Qi Zhi Institute

Full-time ResearcherOn-site · Advised by Prof. Huazhe Xu, Tsinghua University

Researching robot learning and embodied intelligence through physical robot platforms and real-world experiments.

2025.07 – 2026.06

Prof. Zhao Kang’s Research Group, UESTC

Undergraduate ResearcherAdvised by Prof. Zhao Kang

Studied graph representation learning, graph prompting, optimal transport, and intrinsic graph geometry, leading to the two publications above.

2024 – Present

University of Electronic Science and Technology of China (UESTC)

B.E. in Computer Science and TechnologyNational “Everest Plan” Project

Undergraduate study in computer science and technology.

Selected Project

Non-linear Classifiers Generalized from Linear Classifiers

University of Cambridge Project Leader

Supervised by Prof. Jamie Vicary Professor of Future Computation, University of Cambridge

Best Team · Best Individual · Highest personal score: 84/100

Derived optimization equations for minimizing classification error, implemented a linear classifier, and generalized the mathematical model toward nonlinear classification.

Leadership & Interests

Class President, National “Everest Plan” Cohort, UESTC Excellent Student Leader

Beyond research Tennis · Drums

News

Joined Shanghai Qi Zhi Institute as a full-time, on-site researcher in robot learning under Prof. Huazhe Xu (Tsinghua University).

“Preserving Geometric Integrity in Graph Prompting via Measure-Constrained Optimal Transport” received a Major Revision decision from IEEE TPAMI.

“The Post-GCN Decade Revisited: Curvature-Stratified Evaluation of Relational Learning” was released as an arXiv preprint and submitted to NeurIPS 2026.